[IML/02] · Workshops
FabNodes: Detangling Dependencies
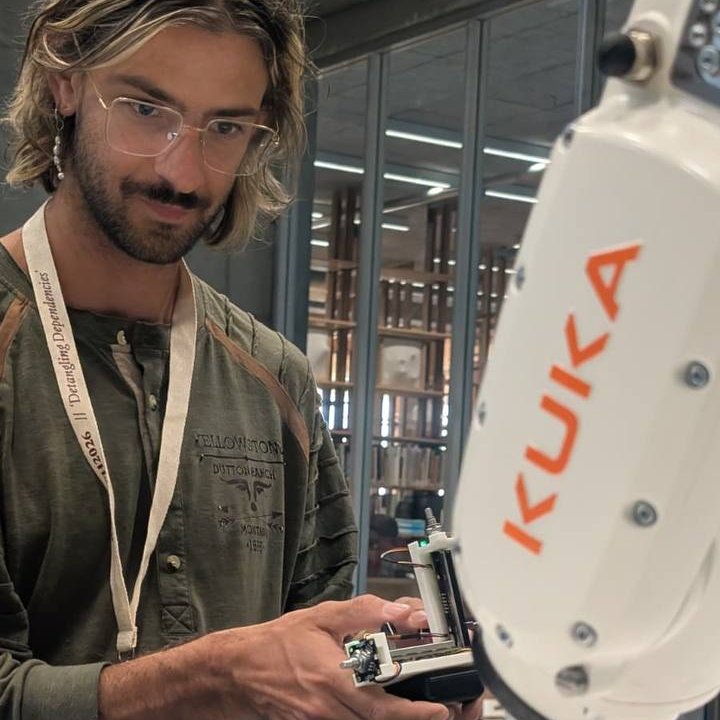
FabNodes was a three-day workshop at ROB|ARCH 2026, Robots in Art, Architecture and Design, held at the Aarhus School of Architecture in Denmark. It received the Best Workshop award.
The workshop treats every end effector as an autonomous, network-addressable device rather than a robot peripheral. Each tool carries an ESP32, joins ordinary studio Wi-Fi and exposes readable and writable attributes over MQTT, so the robot controller does one job: motion. Teams planned and drove the robots in Blender with the Animaquina add-on and the open Fab-Nodes electronics toolkit.
Eight participants worked in four teams on two KUKA arms, a KR 10 R-900-2 and a KR 6 R-900-2. No end effectors were handed out: each team designed and built its own tool.
Video
Team projects
- Rock, Paper, Robot by Emre Ergin: webcam hand tracking moves the robot’s target in Animaquina’s Puppet mode, with a hand-gesture game against the robot shown on an MQTT LED matrix.
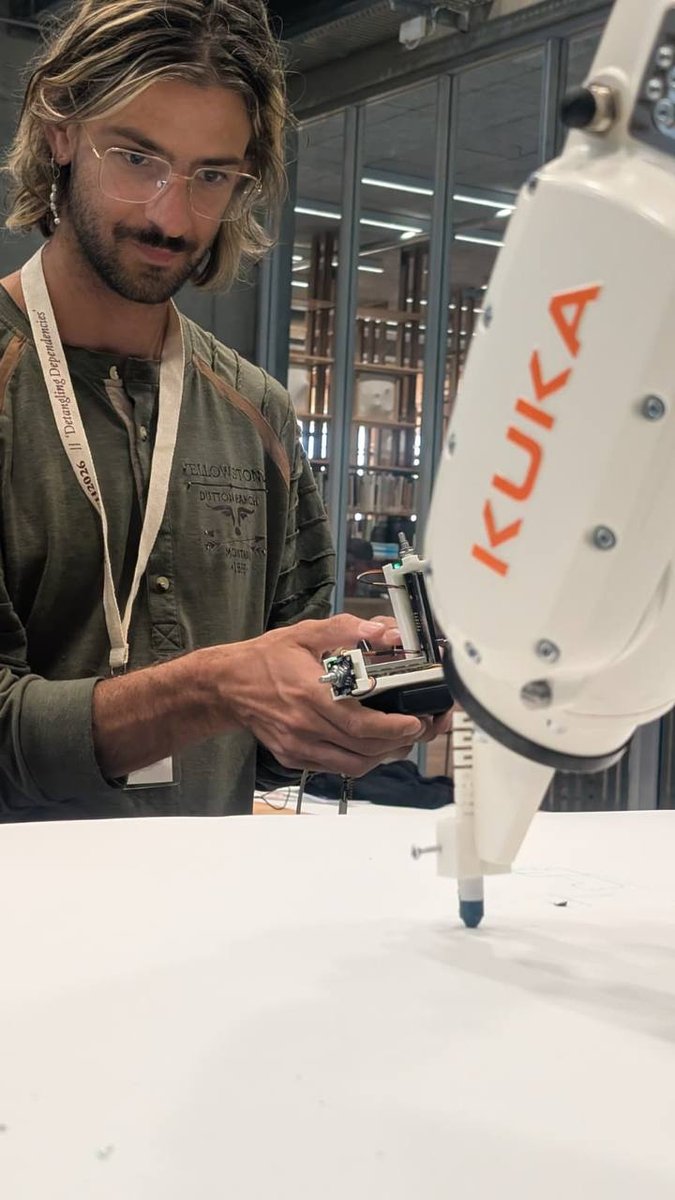
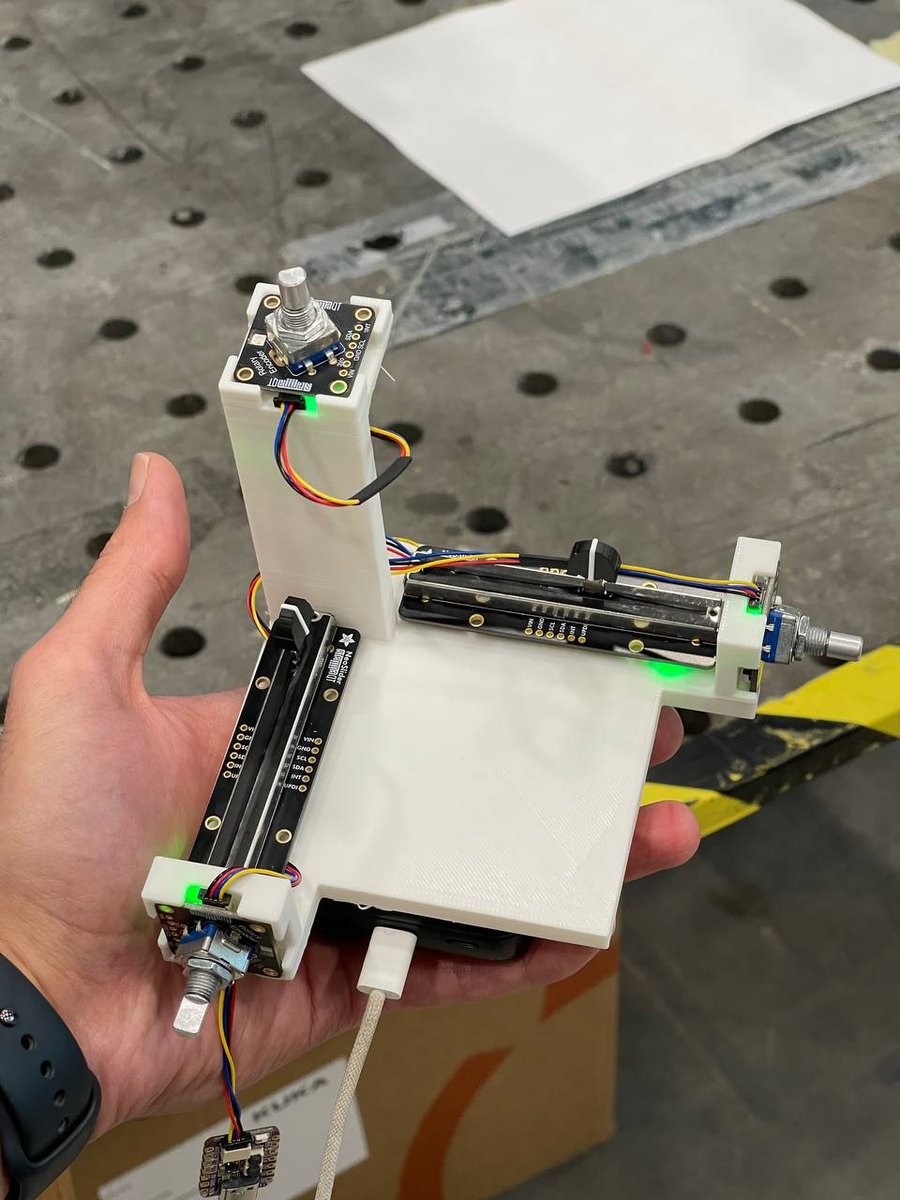
- The Physical 3D Gizmo by Mehryad Esmaeili Charkhab and Mirko Gerber: a handheld controller of sliders and rotary encoders that moves the robot live, paired with a pen holder so every input becomes a drawing.
- The Typewriter by Daniel Sviták, Adam Varga and Mirko Gerber: a six-solenoid end effector that stamps braille into clay, one character at a time.
- Real-Time Adaptive Toolpaths by Derek Kawiti, Ludovic Mallegol and Rodrigo Shiordia: a time-of-flight sensor measures the distance to the surface below, and Blender corrects the toolpath height live over a surface that was never scanned.
Gallery
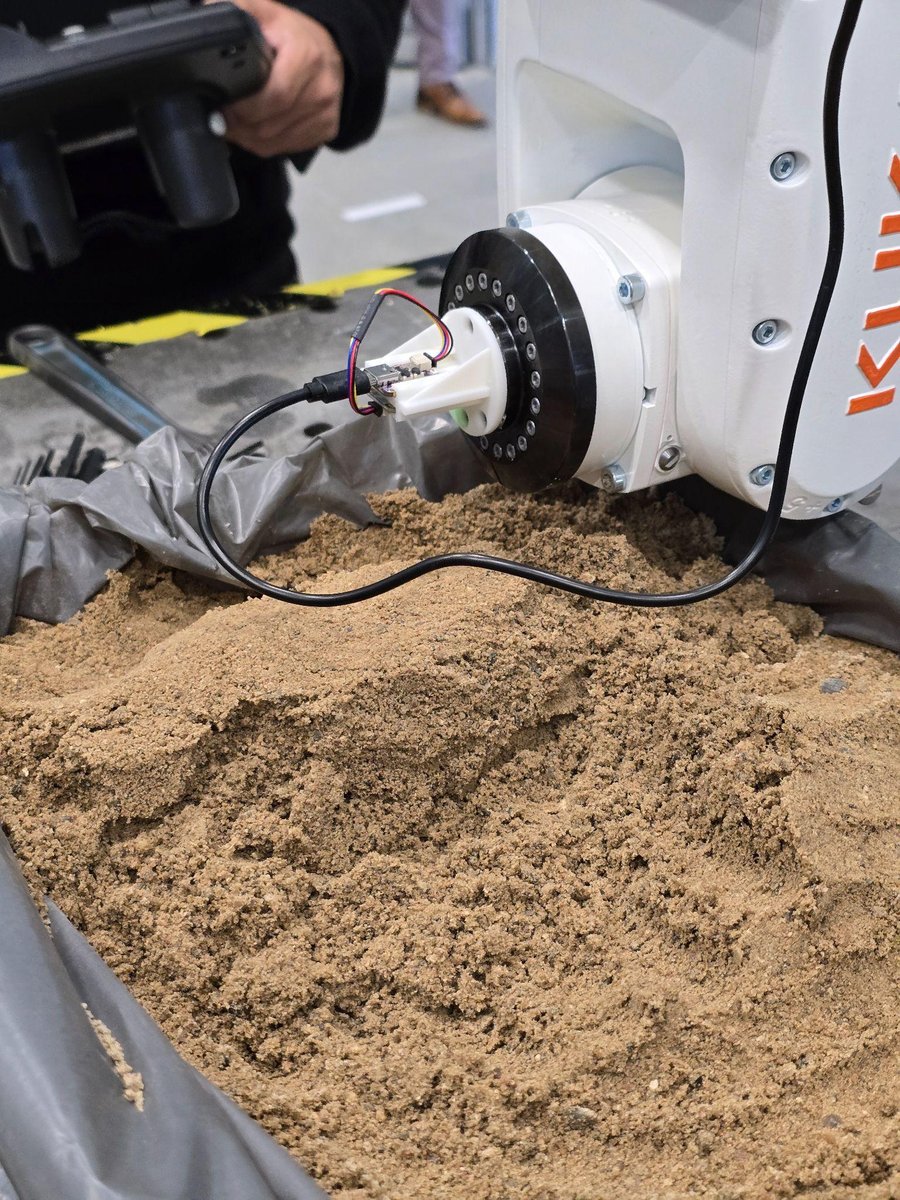
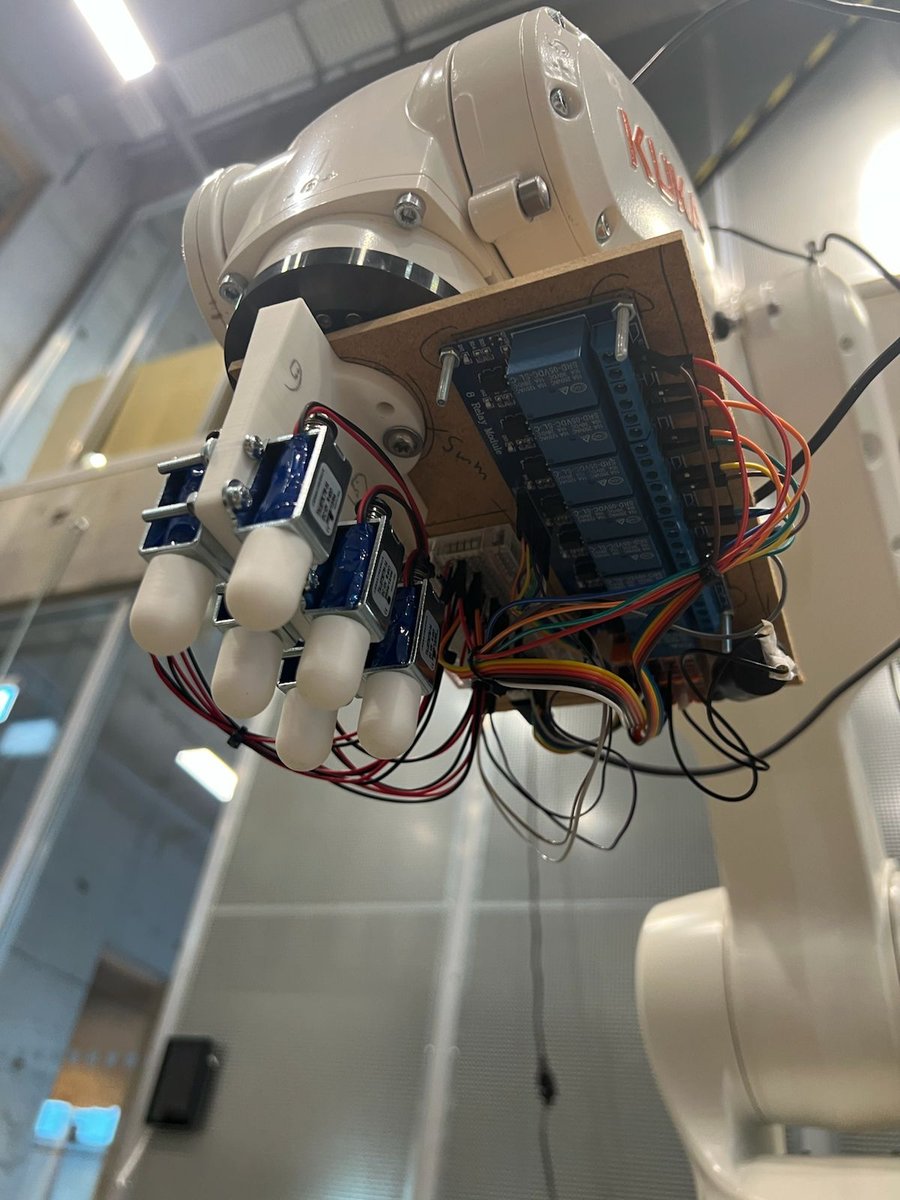
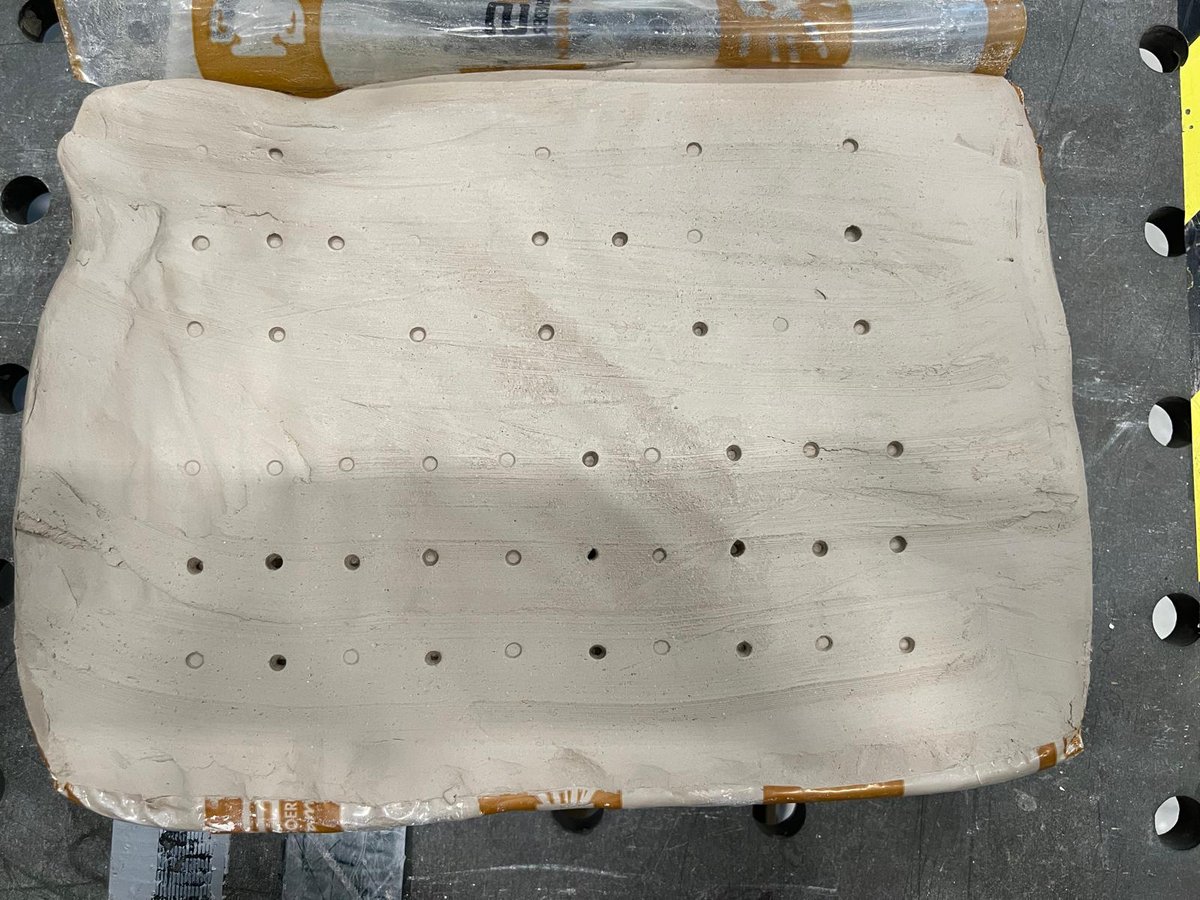
Photos by the FabNodes workshop teams, shared under CC BY 4.0.